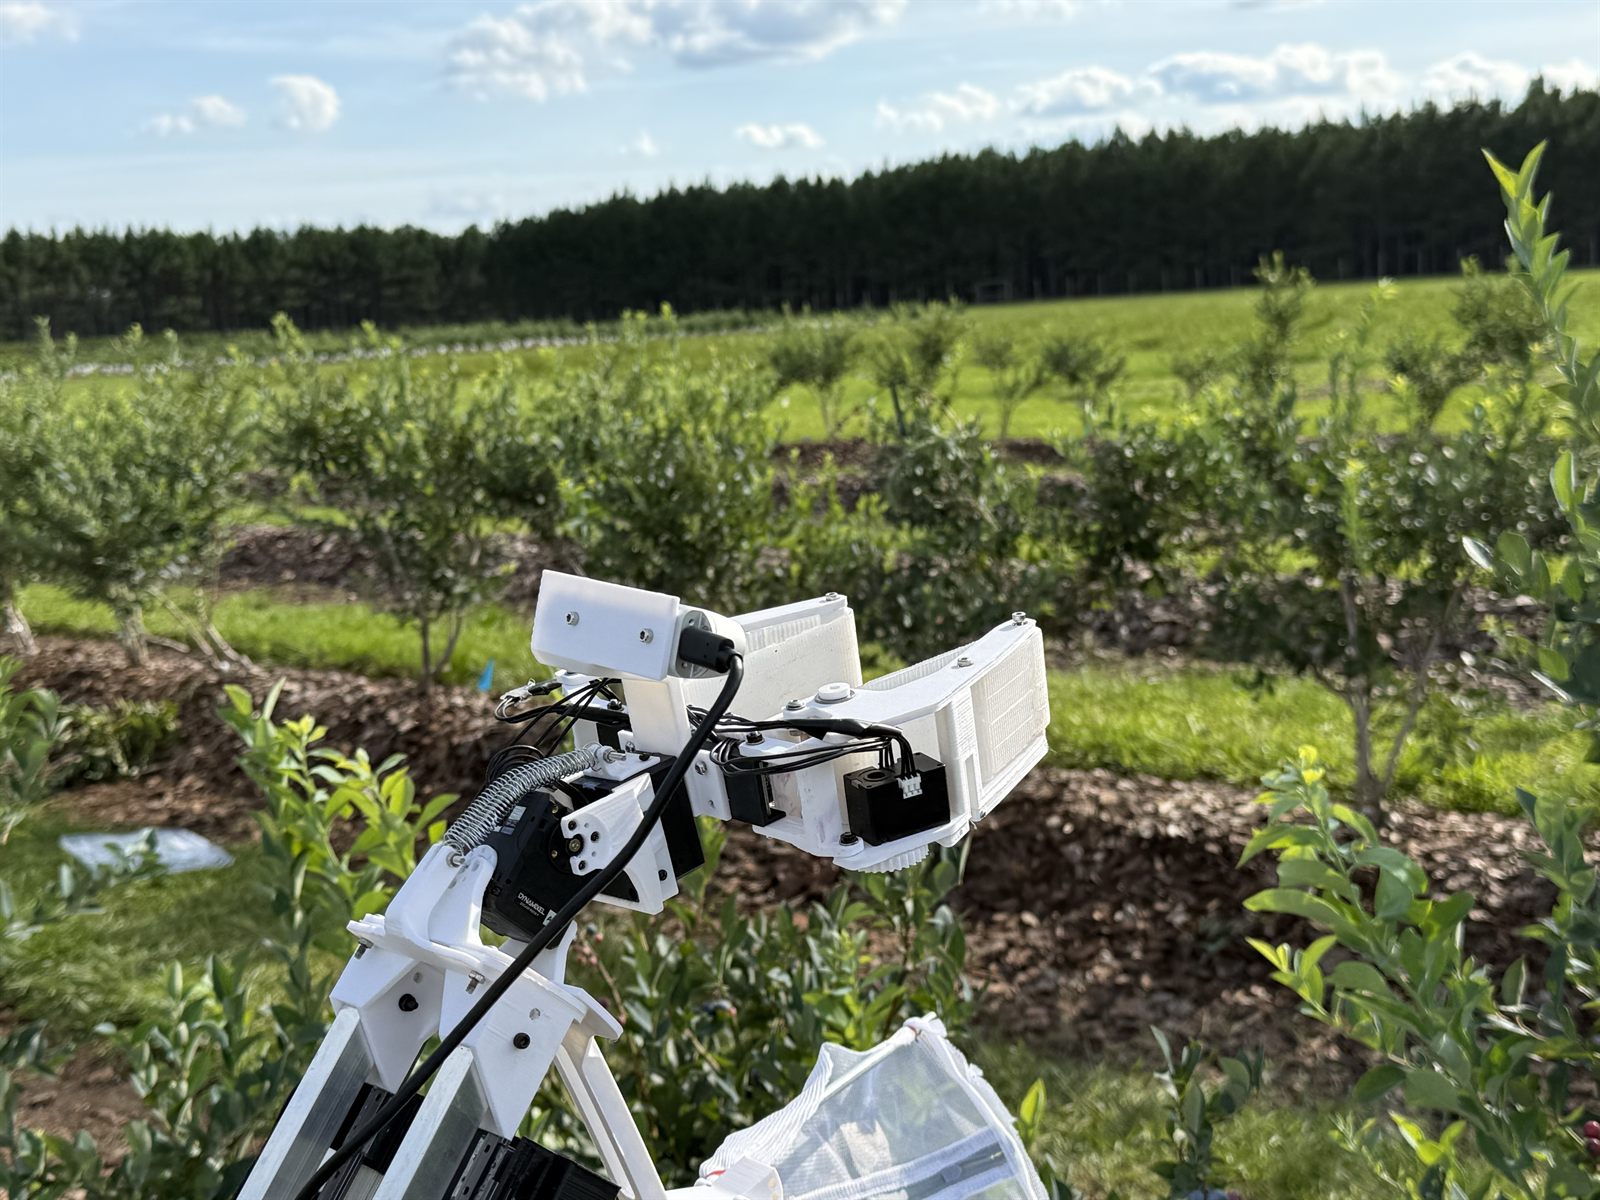
A 6-DOF harvesting arm with a current-based, force-aware rolling gripper that locates, approaches, and gently detaches ripe blueberry clusters.
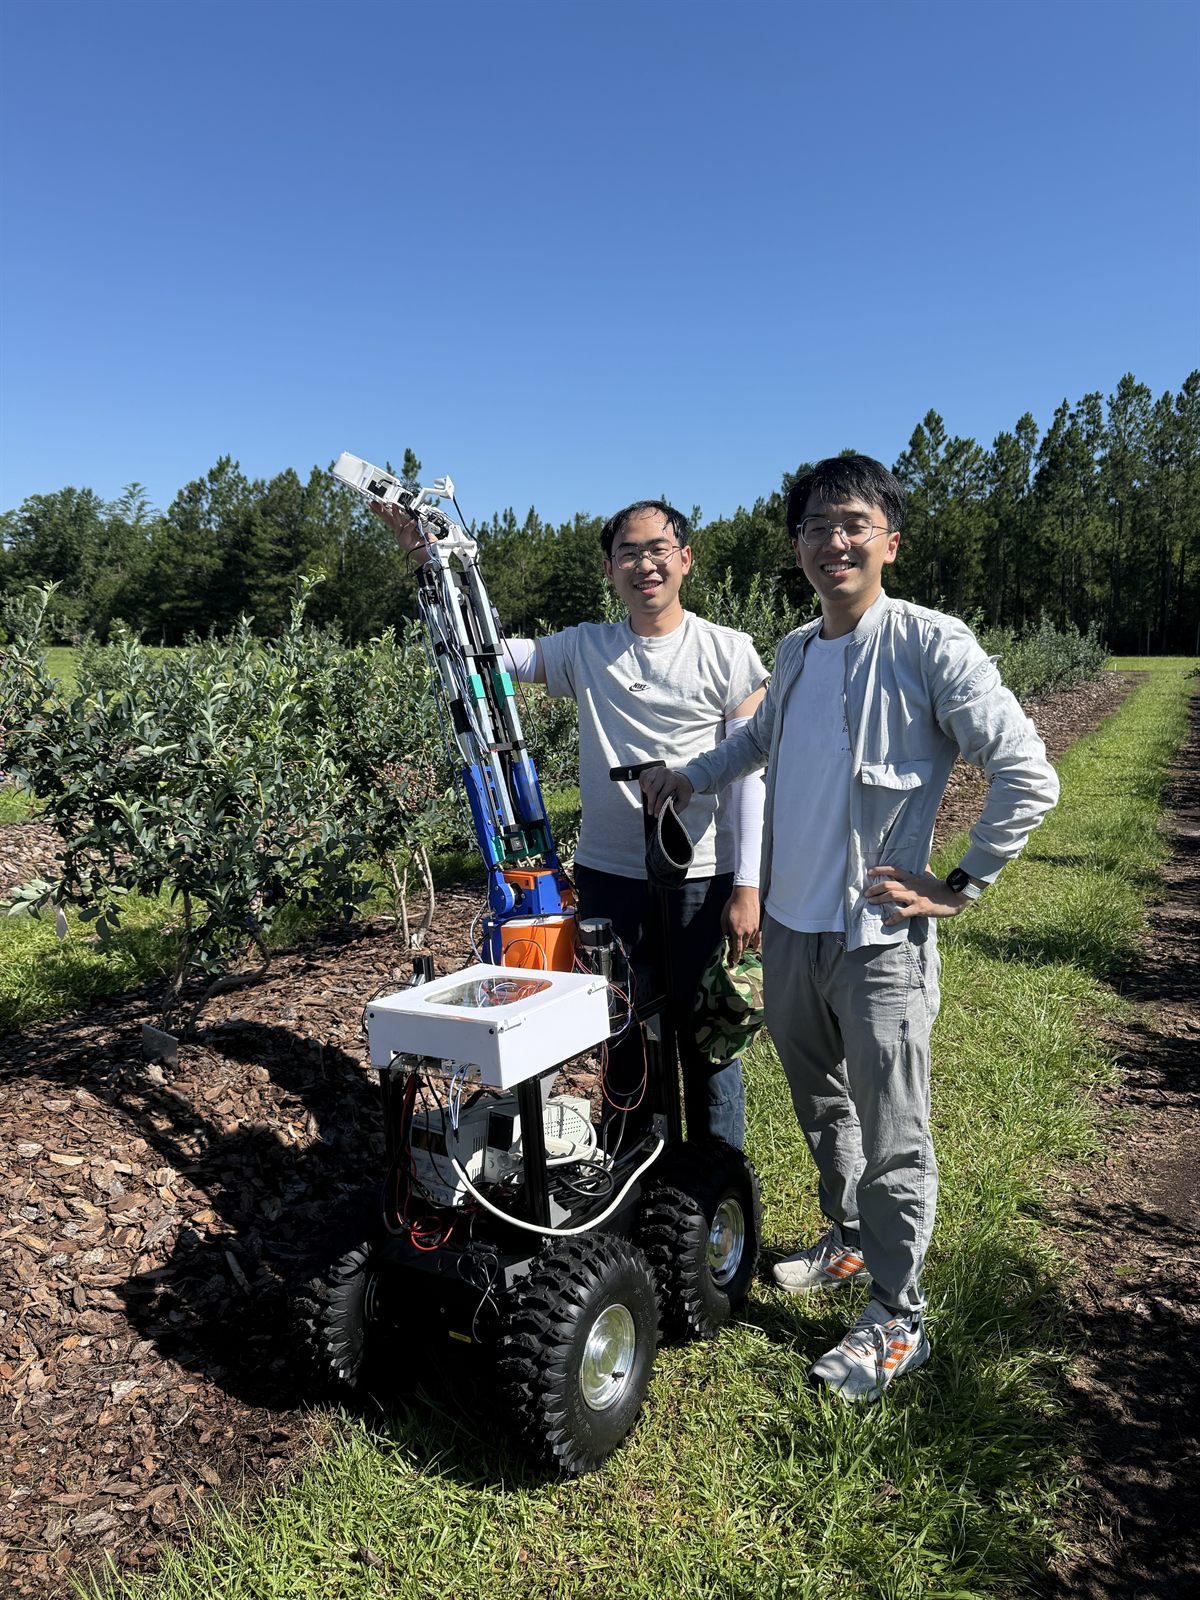
The platform deployed on a commercial blueberry row โ a tracked mobile base carrying the arm, the perception stack, and a collection bag.
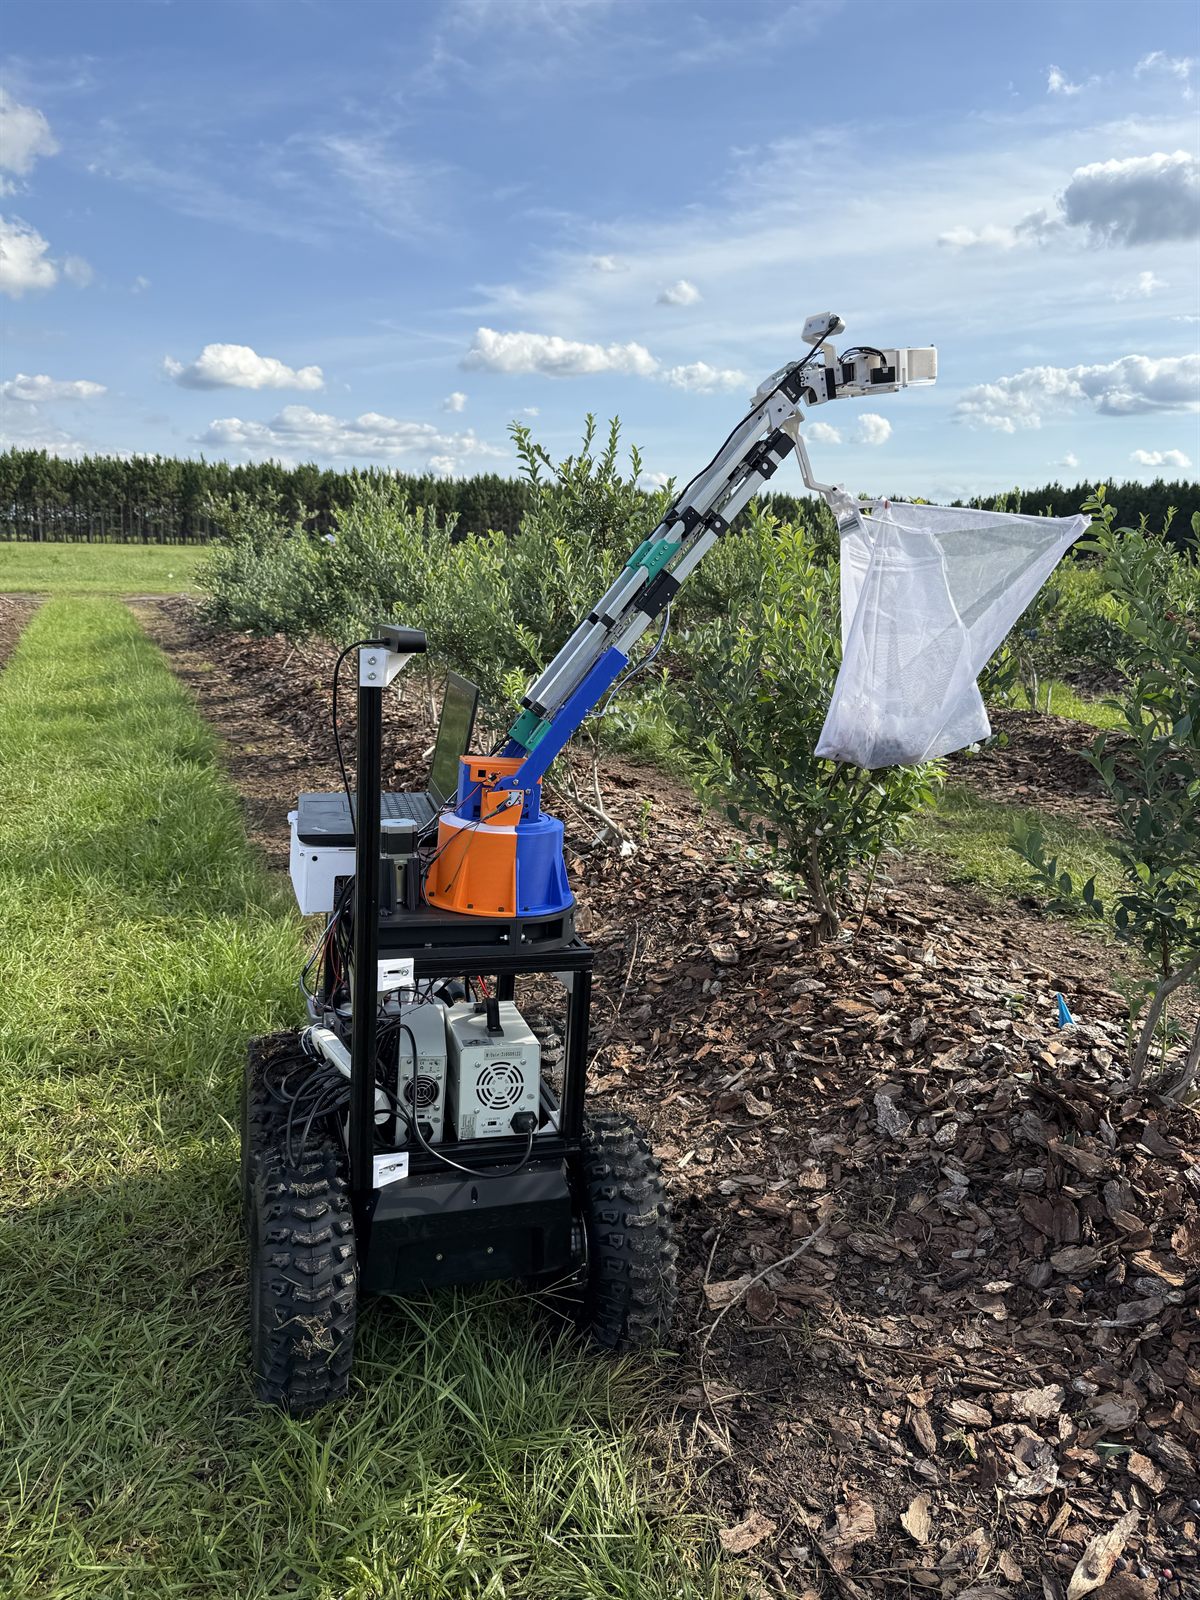
A global camera scans the bush and proposes cluster waypoints; the arm presents an in-hand camera for close-range visual servoing; a soft rolling gripper grasps and detaches while watching motor current, so it never crushes the fruit.
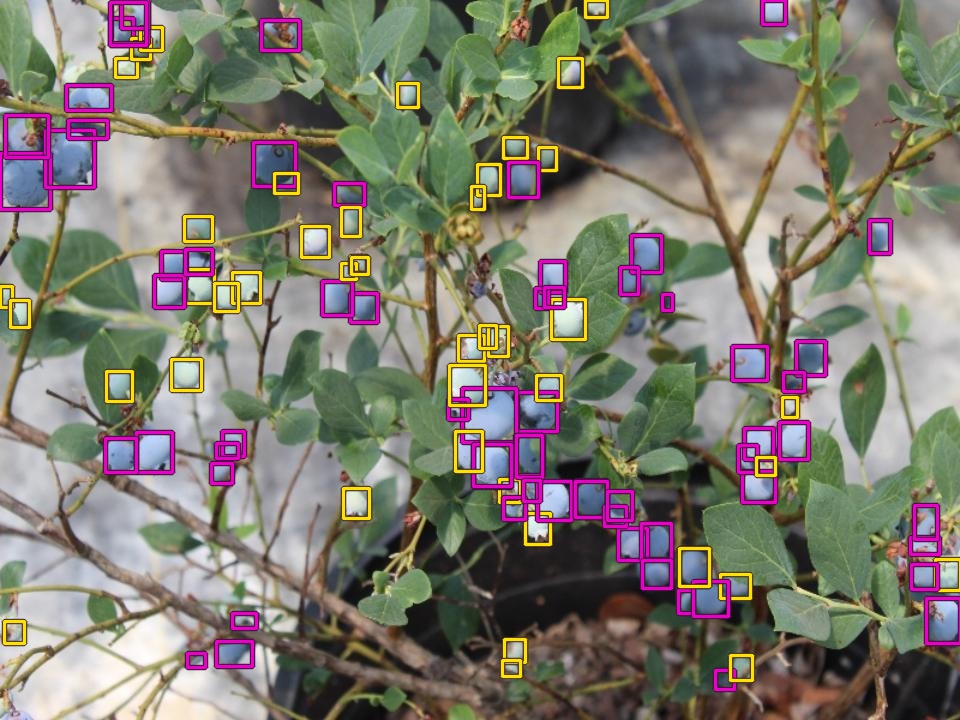
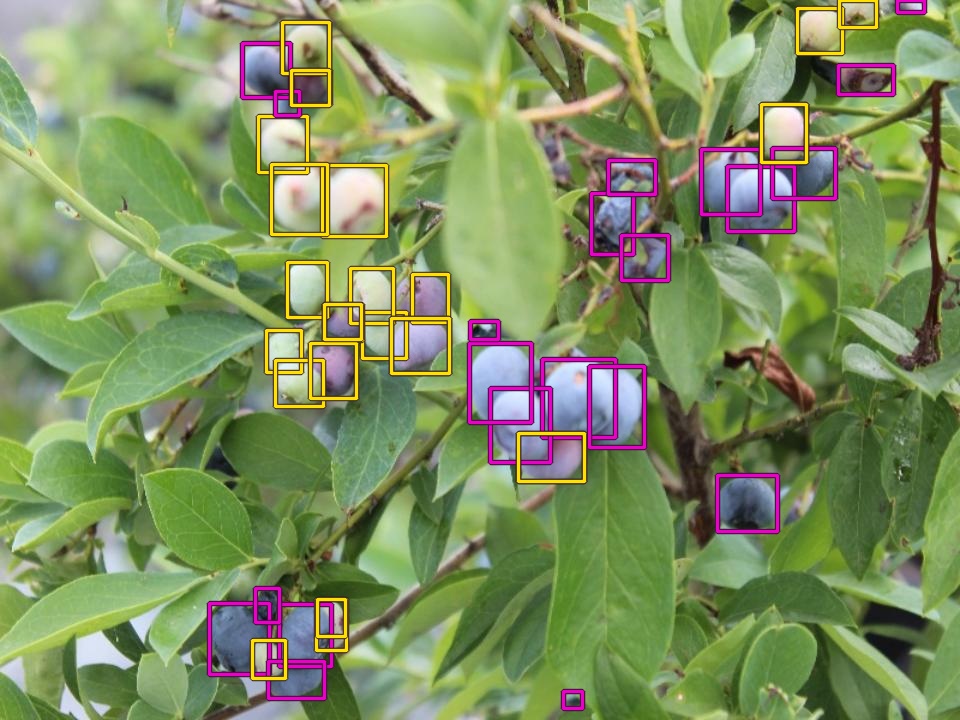
YOLO cluster detection, an ArUco-anchored world frame, and PCA orientation estimation feed 3-D harvest waypoints.
Analytic-seeded numerical IK solves both position and the radial approach orientation needed for grasping.
Current feedback clamps and detaches clusters gently โ the core research contribution.
The hardware, as configured in the control pipeline.
| Arm | RRP arm (pitch ยท yaw ยท prismatic) + wrist (yaw ยท pitch ยท roll) |
|---|---|
| Cameras | Stereolabs ZED global (HD1080) ยท Intel RealSense in-hand (640ร480 + depth) |
| Gripper | 2 grasp fingers + 2 rolling bands (Dynamixel XM) ยท current sensed at ~3.36 mA/count |
Delicate fruit bruises under low force. Rather than adding a tactile sensor, the gripper infers contact force from Dynamixel motor current โ taking that from binary contact detection to calibrated, regulated force control.
Ramp closure against a force sensor; log current vs. force, up and down for hysteresis.
Fit F = mยทI + b; locate the current at a configurable bruise-force threshold.
A model-based controller drives estimated clamp force to a target in Newtons.
Overshoot, settling time and time-above-bruise vs. the threshold controller.
The Wallace H. Coulter Department of Biomedical Engineering, Georgia Institute of Technology.
If you use this work, please cite it. TODO: confirm the final title, venue, and year.
@misc{blueberry_harvester,
title = {Autonomous Blueberry Harvesting with a Force-Aware Rolling Gripper},
author = {Xia, Yixuan and Cai, Yilin and Wilcox, Samuel E. and Chen, Yue},
year = {2026},
note = {https://github.com/StopHere1/autonomous_blueberry_harvester}
}
Code, setup instructions and the full experiment toolkit live in the GitHub repository.